← All demonstrations

Machine Learning / Evaluated demonstration

Dynamics Atlas

Combine physical simulation and clustering to explore motion patterns.

WHO IT HELPS
Scientific research, simulation and dynamic-signal analysis.
WHAT IT DOES
Combine physical simulation and clustering to explore motion patterns.
DEMO OUTPUT
Trajectory, animated phase portrait, embedding, neighbours and JSON analysis.
Scope a Machine Learning pilot →

Actual recording · Explanatory English captions · Original synthetic data

Recorded demonstration of a functional local application. A pilot defines data, access and deployment; this website serves the video and screenshots.

THE PROBLEM

Nearby configurations can produce very different trajectories.

THE WORKFLOW

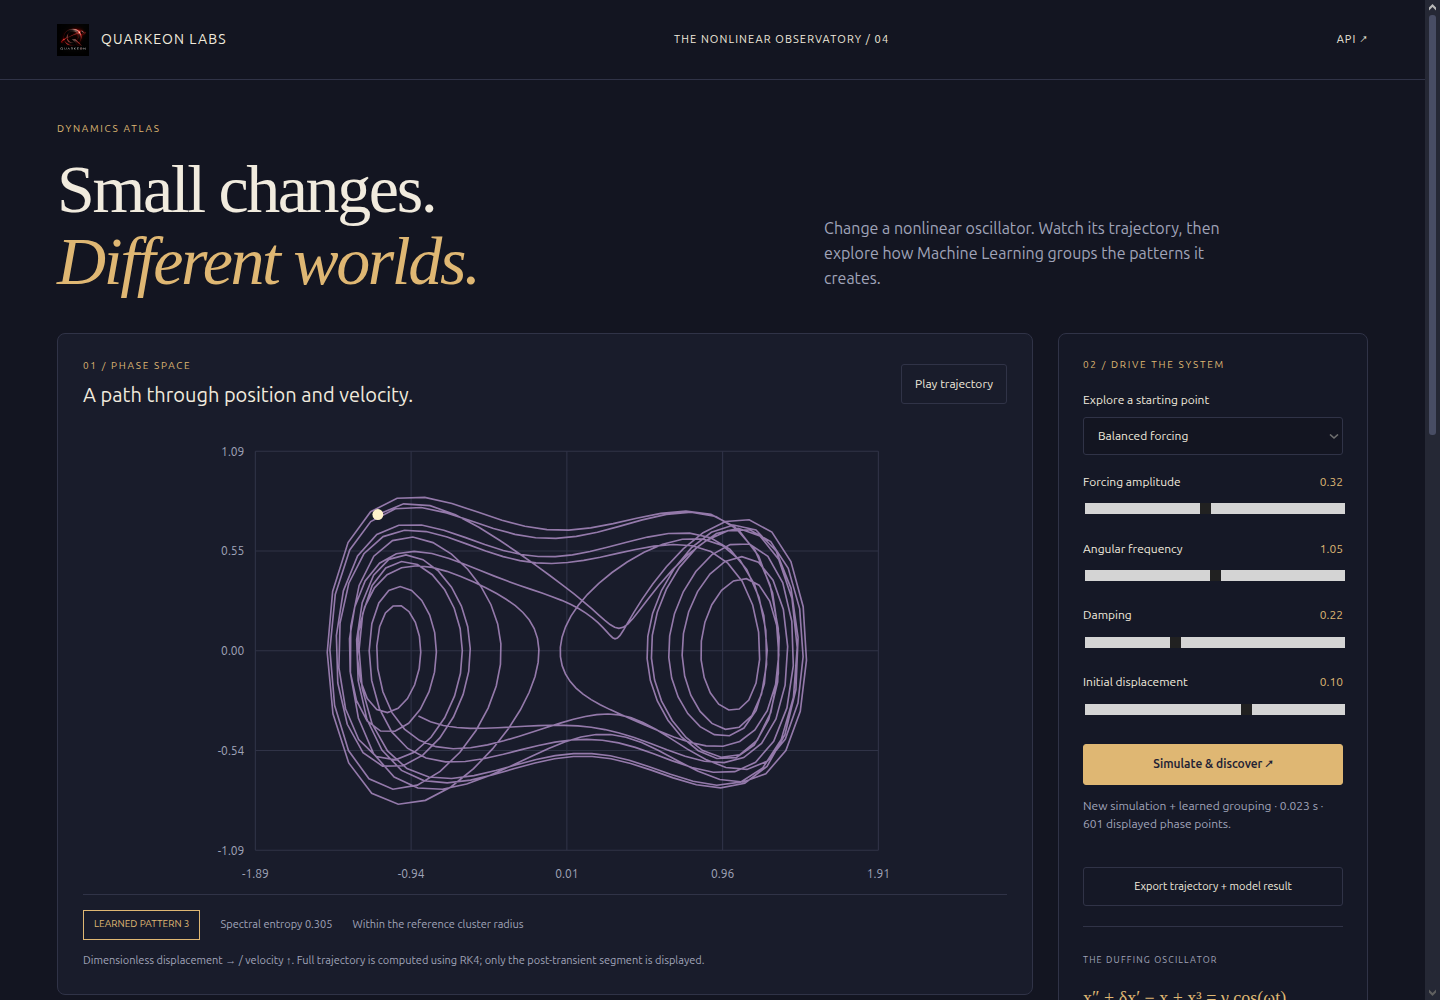
RK4 integrates a Duffing oscillator and extracts seven features. A model trained on 160 trajectories learns a PCA embedding and four clusters. Change amplitude, frequency, damping and initial position; animate the phase portrait and compare neighbours, spectrum and Poincare section.

  1. 01Select a preset or change four parameters.
  2. 02Animate the phase portrait and inspect the trajectory.
  3. 03Compare learned patterns and neighbouring trajectories.
  4. 04Review spectrum, Poincare section and export.

RECORDED EVIDENCE

Results, with context.

Checks on heldout synthetic examples
CheckCases
Documented checks; synthetic data30 of 30
Dataset
synthetic-duffing-trajectories-v1
Completed cases
30/30
Median / p95 per case
0.004198020500552957 s / 0.0048012007478973814 s
Evaluation record (UTC)
2026-10-10

30 trajectories with heldout seeds pass numerical and output checks. Training silhouette is 0.680; this is not accuracy. A short RK4 step comparison at 0.01 and 0.005 yields a maximum error of 6.67 × 10⁻¹⁰. Timings measure simulation and analysis on CPU, excluding HTTP and training.

WHAT WE COULD BUILD WITH YOU

A simulation explorer for comparing and reviewing patterns.

What we would define first

Equations, units, parameter domain, solver, observables and numerical validation.

Demonstration limits

Simulated dimensionless system. Clusters are learned patterns, not physical labels or proof of chaos. The 30 checks verify integration and valid outputs; they do not measure regime-classification accuracy.

Scope a Machine Learning pilot ↗
Screenshot of the interface for Dynamics Atlas
Demonstration review interface.

Explore other projects