 Recorded demo
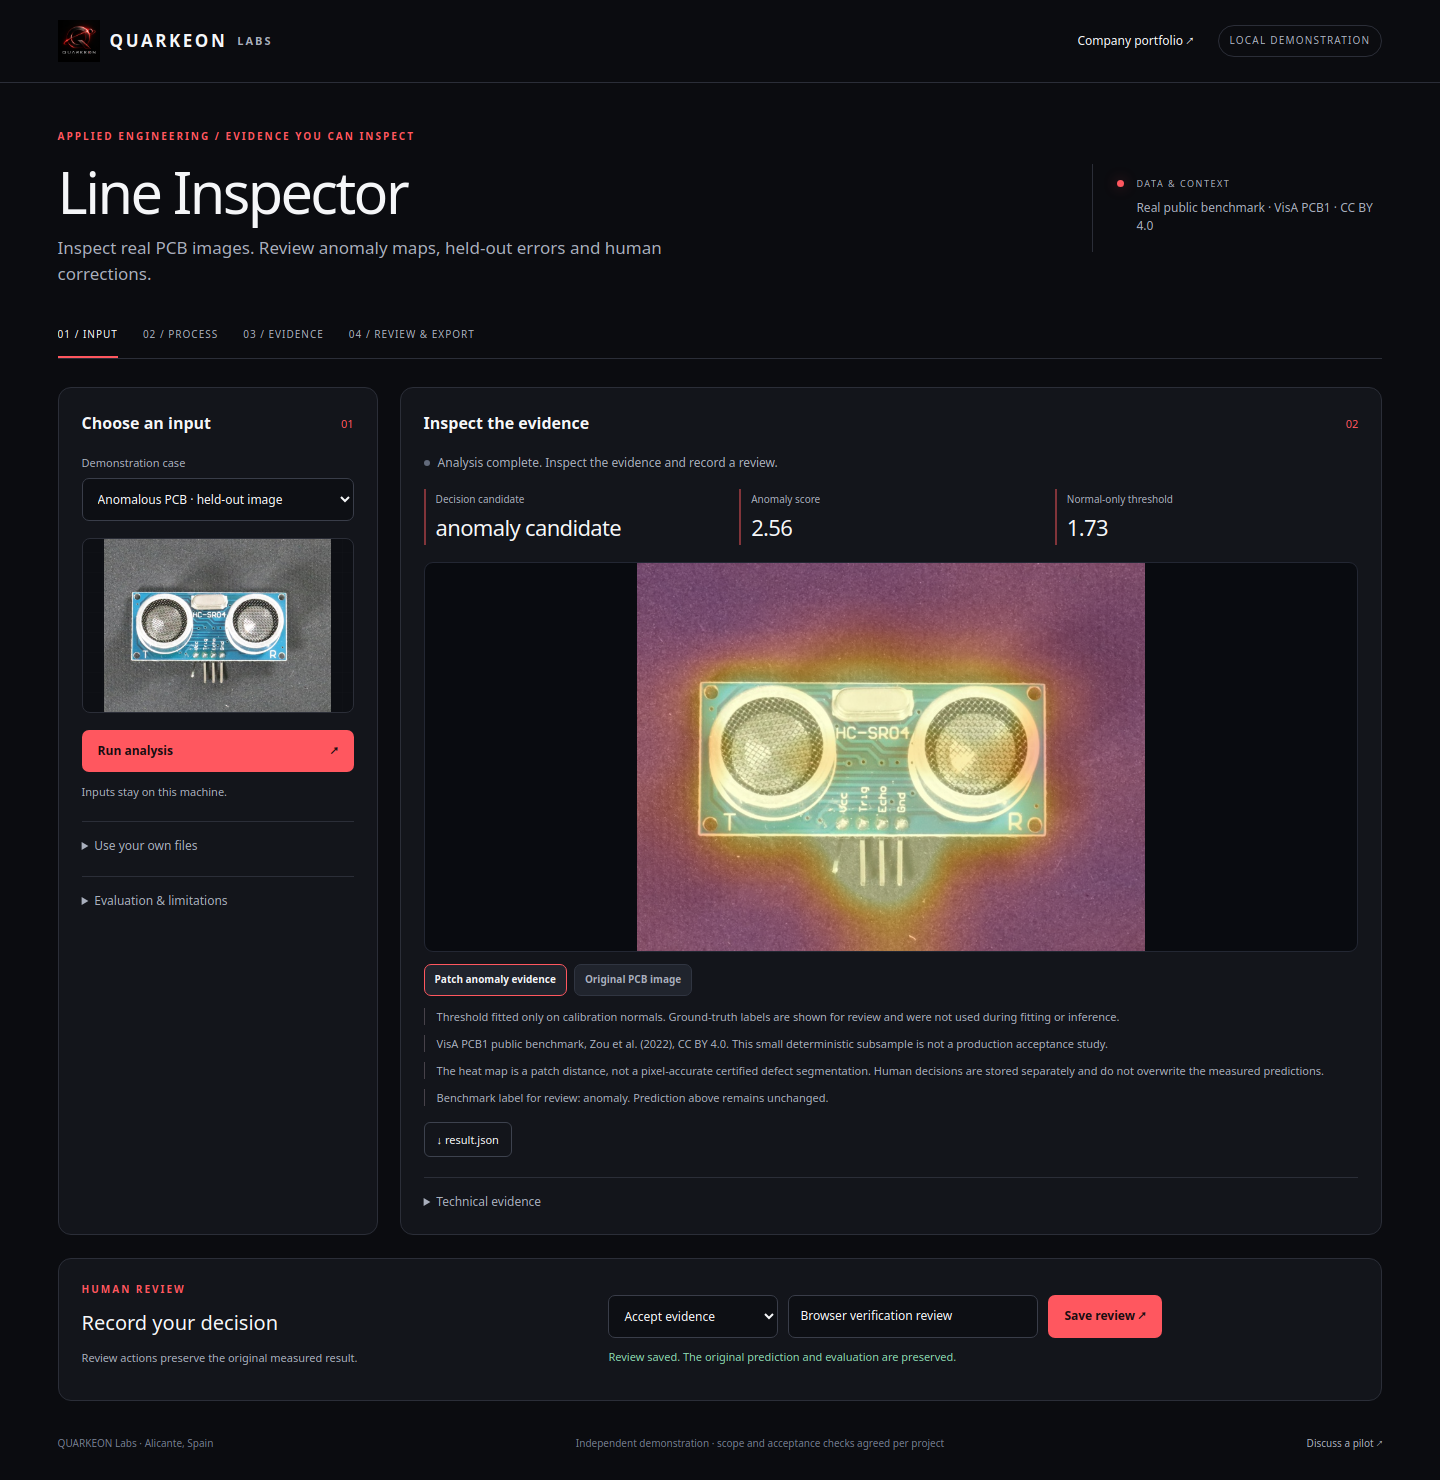
Line Inspector
Inspect real circuit boards and review anomalies and errors.
76 of 80 cases · Real images · VisAHeld-out images correctly classified
Watch the demoVision / Evaluated demonstration
Reconstruct cameras and 3D geometry from photographs.
Actual recording · Synthetic English narration and captions · Real photographs
THE PROBLEM
THE WORKFLOW
COLMAP runs SIFT extraction, matching, triangulation and bundle adjustment. All 33 public photographs registered in one model with 16,844 points. The viewer lets you explore the reconstruction and estimated cameras.
RECORDED EVIDENCE
| Check | Cases |
|---|---|
| Photographs registered in the model | 33 of 33 |
Source: local pipeline execution on the identified inputs. CPU; no GPU. HTTP timings refer to the interface samples; for reconstruction they measure loading recorded geometry, not a new reconstruction. These are not customer outcomes or a guarantee on other data.
WHAT WE COULD BUILD WITH YOU
Static textured object, coverage, camera, scale references and the exact required 3D asset.
One CC BY 4.0 public photo set by alansartlog. Sparse reconstruction at arbitrary scale, without external accuracy measurements. It is not a dense or textured mesh. The initial button loads the recorded result; uploading photos runs a new reconstruction.
Discuss photo reconstruction ↗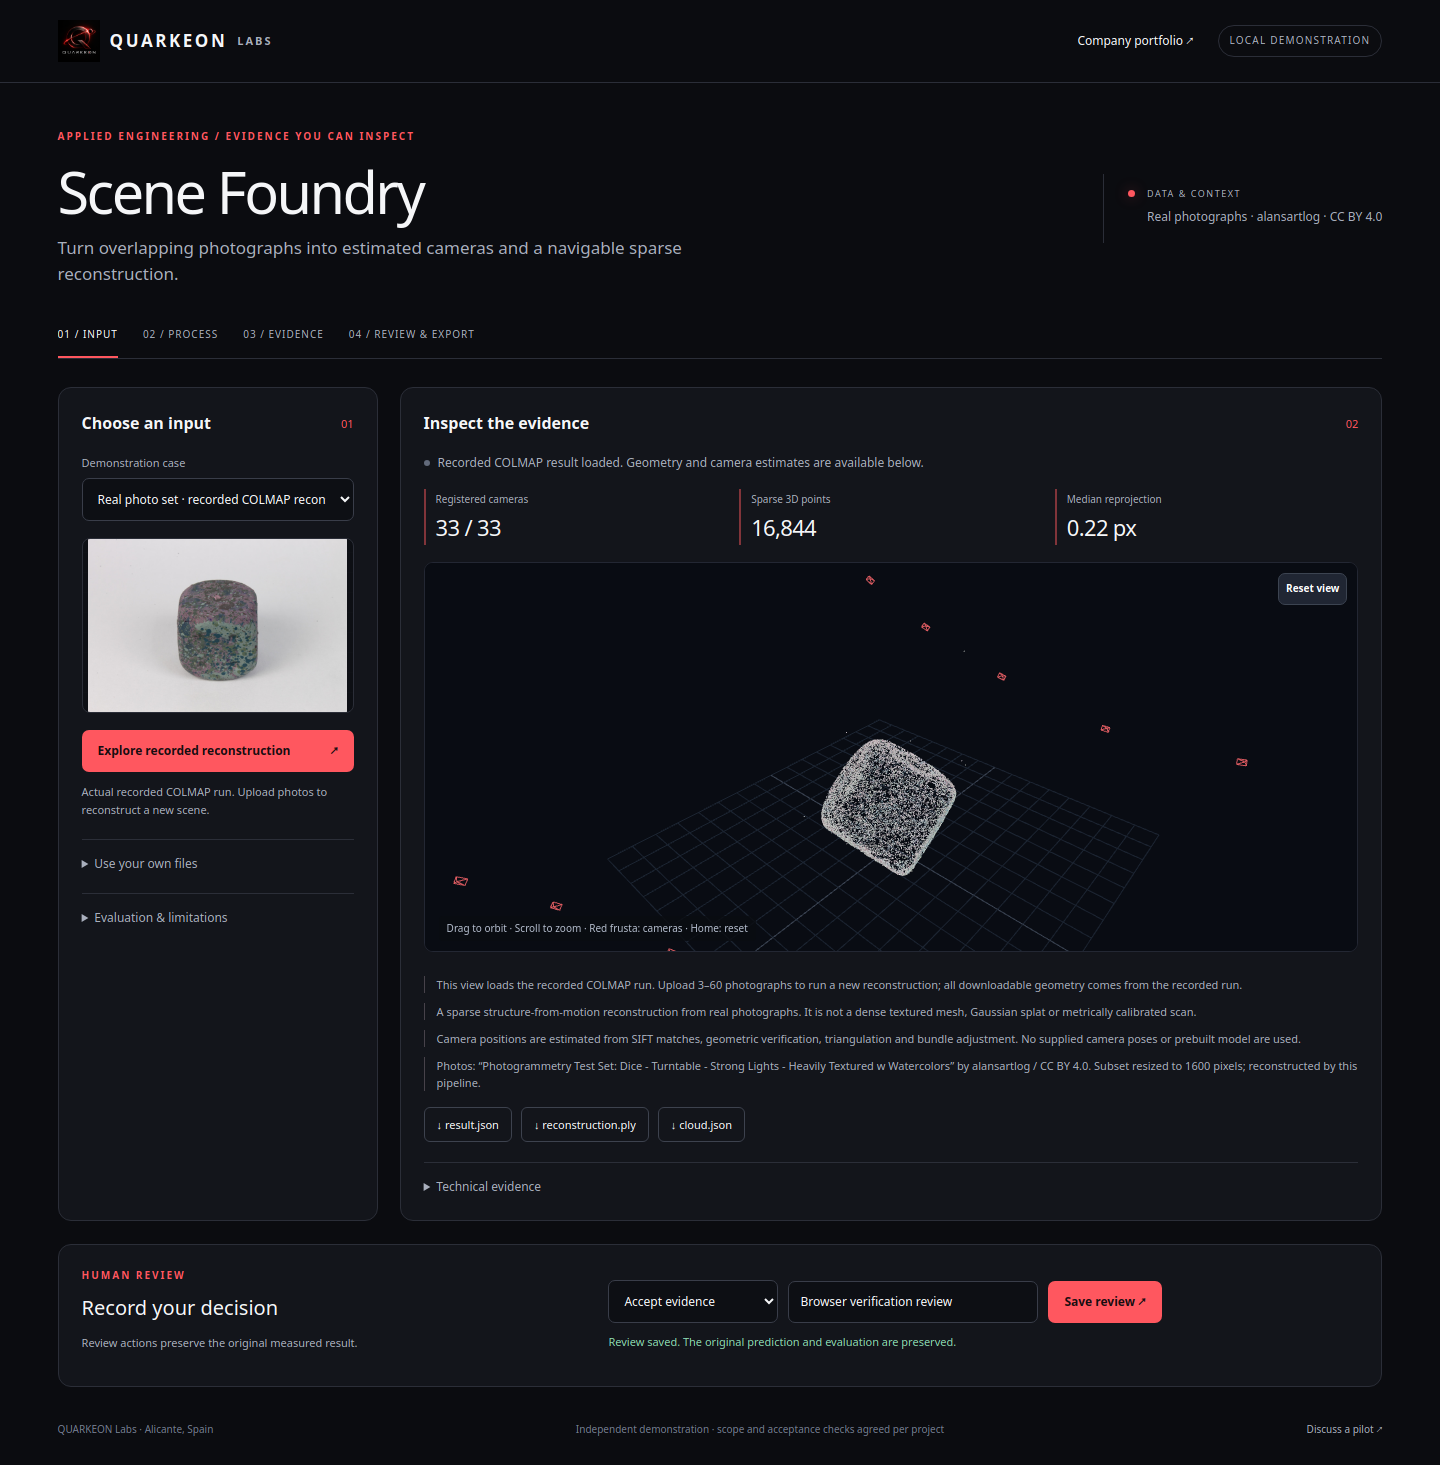 Recorded demo
Inspect real circuit boards and review anomalies and errors.
76 of 80 cases · Real images · VisAHeld-out images correctly classified
Watch the demo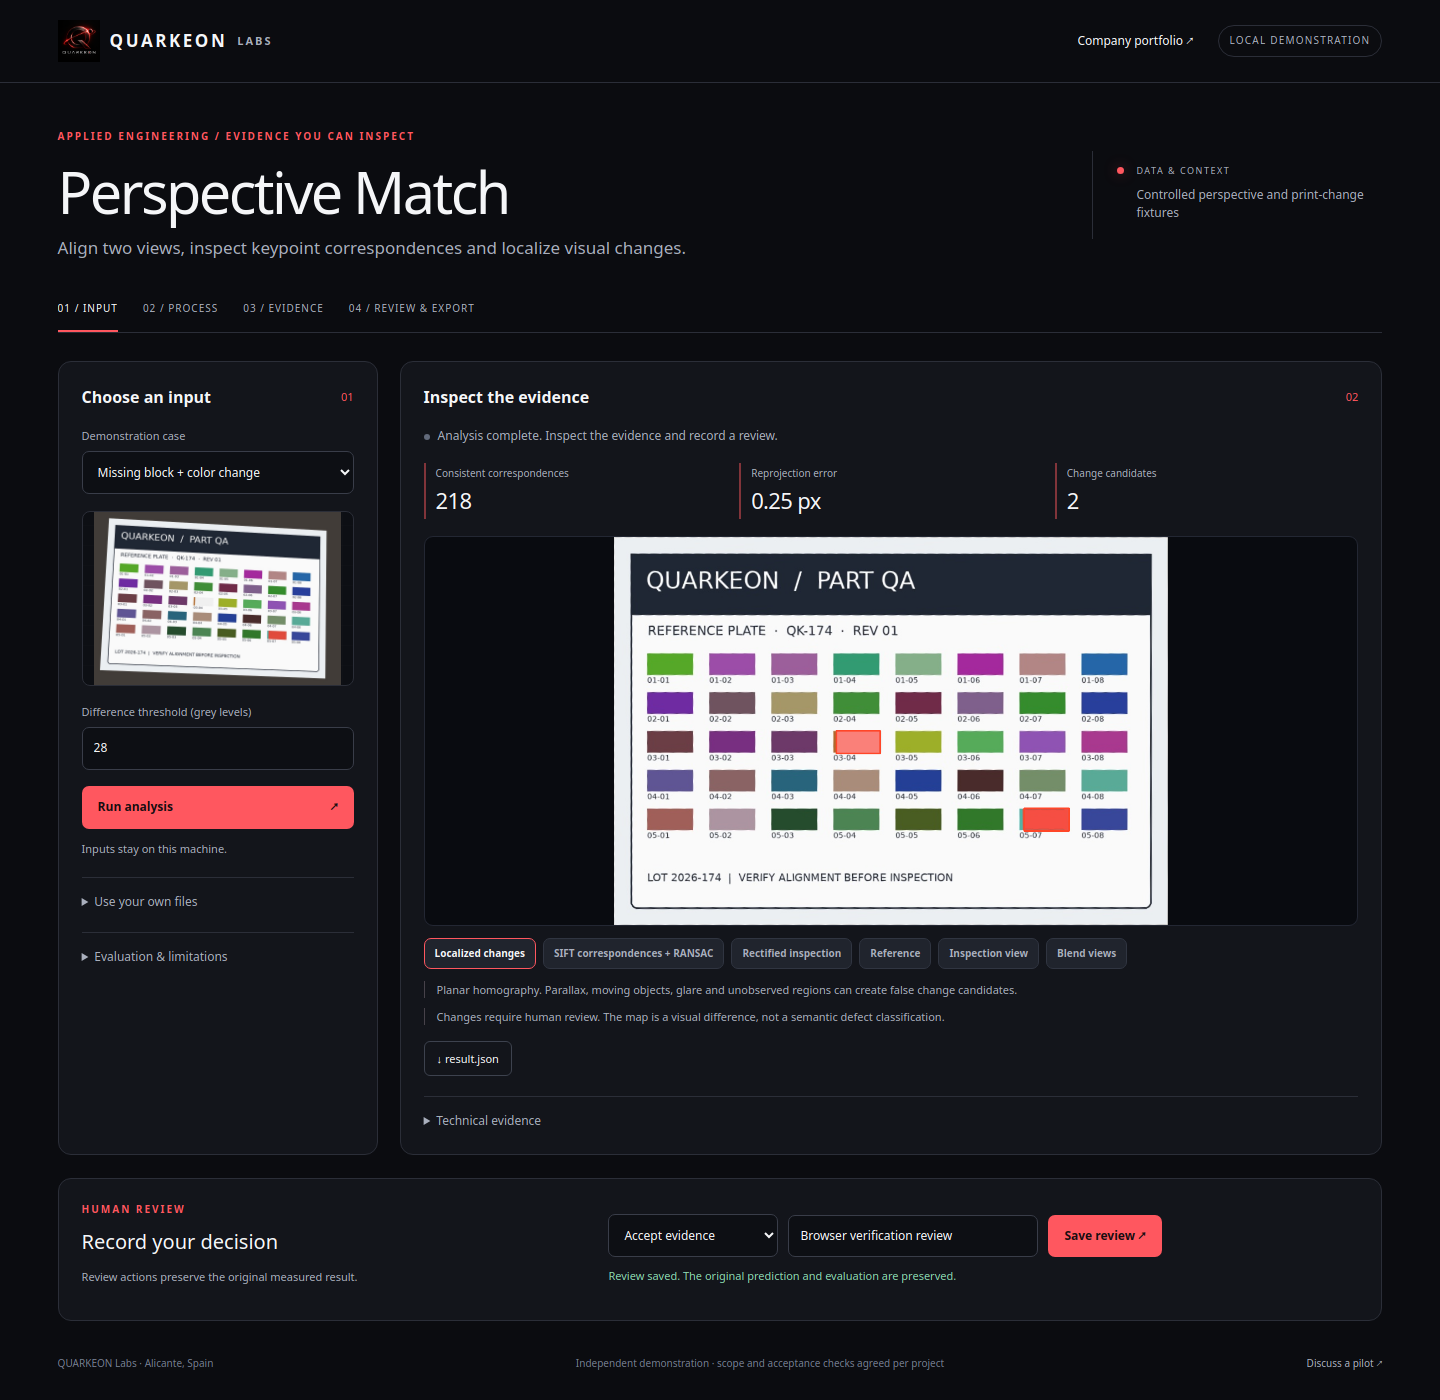 Recorded demo
Align two images and localize visual differences.
12 of 12 cases · Simulated image pairsPairs with corner error below 2 px
Watch the demo